Control of Complex Systems

949,00 RON
+ 29,99 RON Livrare

Control of Complex Systems
Vândut de:

949,00 RON

În stoc
+ 29,99 RON Livrare

Politica de retur pe 14 zile

Protecție cumpărător

Metode de plată:

  • Marcă: Unbranded

Detalii produs

Detalii produs

Control of Complex Systems

1. Introduction. - 1. 1 Complex Systems and Control. - 1. 2 Complex Engineering Systems. - 1. 3 The Role of Feedback. - 1. 4 Dynamics and Control. - 1. 5 The Nature of Failures. - 1. 6 Research Challenges. - 1. 7 About the Book. - 2. Modeling Complex Physical Systems. - 2. 1 Introduction. - 2. 2 The Modelica Project. - 2. 3 Composition Diagrams. - 2. 4 Modelica Details. - 2. 5 Non-causal Modeling. - 2. 6 Advanced Modeling Features. - 2. 7 Standard Libraries. - 2. 8 Future Development. - 2. 9 Conclusions. - 3. Passivity-based Control of Non-linear Systems. - 3. 1 Introduction. - 3. 2 Passivity and Stability Analysis of Feedback Interconnections. - 3. 3 Feedback Passivity and Stabilization. - 3. 4 Euler-Lagrange Systems. - 3. 5 Disturbance Attenuation and R oo Control. - 4. An Introduction to Forwarding. - 4. 1 Introduction. - 4. 2 C1 Dissipative Systems. - 4. 3 C1 Dis sipative Systems via Reduction or Extension. - 4. 4 Exact Change of Coordinates. - 4. 5 Approximate Change of Coordinates. - 5. Iterative Identification and Control Design. - 5. 1 Introduction. - 5. 2 Youla Parametrization. - 5. 3 A Generic Two-degree of Freedom Controller. - 5. 4 Optimization of the Generic Scheme. - 5. 5 A New Closed-loop System Parametrization. - 5. 6 Asymptotic Variances for K-B-Parametrization. - 5. 7 Iterative Controller Refinement. - 5. 8 Robustness and Sensitivity. - 5. 9 Product Inequalities. - 6. Learning Control of Complex Systems. - 6. 1 Introduction. - 6. 2 Model Structures for Learning. - 6. 3 Control Structures for Learning. - 6. 4 Learning Paradigms. - 6. 5 A General Framework for On-line Learning. - 6. 6 Validation. - 6. 7 Conclusions. - 7. Software for Complex Controllers. - 7. 1 Introduction. - 7. 2 An Evolving Paradigm. - 7. 3 Emerging Software Concepts. - 7. 4 On to Standardization. - 7. 5 Sample Complex Software Controllers. - 7. 6 The Future of Software for Control. -8. Fault-tolerant Control Systems. - 8. 1 Introduction. - 8. 2 Basic Definitions. - 8. 3 Analysis of Fault Propagation. - 8. 4 Analysis of Structure. - 8. 5 Recoverability. - 8. 6 Autonomous Fault-tolerant Control. - 8. 7 An Example: Ship Propulsio. - 8. 8 Summary. - 9. Fault Detection and Isolation. - 9. 1 The Principle of Model-based Fault Diagnosis. - 9. 2 Signal-based FDI Approach. - 9. 3 Quantitative Model-based FDI Approach. - 9. 4 Qualitative Model-based FDI Approach. - 9. 5 Summary. - 10. Residual Generation for FDI in Non-linear Systems. - 10. 1 Introduction. - 10. 2 Algebraic Approach. - 10. 3 Geometric Approach. - 10. 4 Conclusion. - 11. Predictive Methods for FTC. - 11. 1 Introduction. - 11. 2 Predictive Control. - 11. 3 Embedding Fault Tolerance in Predictive Control. - 11. 4 Model Adaptation and Management. - 11. 5 Modifying Control Objectives. - 11. 6 Current Industrial Practice. - 11. 7 Conclusions. - 12. Three-tank Control Reconfiguration. - 12. 1 The Benchmark Problem. - 12. 2 Reconfigurability Analysis. - 12. 3 Reconfiguration Based on a Qualitative Model. - 12. 4 A Hybrid Approach to Reconfigurable Control. - 12. 5 A Multi-model-based Reconfigurable Control. - 12. 6 A Neural Observer-based Approach. - 12. 7 Conclusions. - 13. Ship Propulsion Control and Reconfiguration. - 13. 1 Introduction. - 13. 2 Ship Propulsion System. - 13. 3 Structural Analysis. - 13. 4 Fault Detection: A Fuzzy Observer Approach. - 13. 5 Fault Detection: Non-linear Approach - 1. - 13. 6 Fault Detection: Non-linear Approach - 2. - 13. 7 Reconfiguration Using Software Redundancy. - 13. 8 Reconfiguration Using Predictive Control. - 13. 9 Summary and Conclusions. - 14. Learning Control of Thermal Systems. - 14. 1 Introduction. - 14. 2 On Thermal System Learning Control. - 14. 3 Controlling Kiln Heat Processing. - 14. 4 Controlling Reheat Furnace Processes. - 14. 5 Hierarchical Control for Quality Ceramic Tiles. - 14. 6 Learning Control ofFBC Combustion. - 14. 7 Conclusions and Future Research. - 15. Vibration Control of High-rise Buildings. - 15. 1 Introduction. - 15. 2 Energy and Information. - 15. 3 Analytical Mechanics and HRB Modelling. - 15. 4 Disturbance Decoupling. - 15. 5 Passivity Based Control. - 15. 6 Engineering Constraints and Feedback. - 15. 7 Feedback Control and Testing. - 15. 8 Conclusions and Future Research. - 16. Control of Helicopters. - 16. 1 Introduction. - 16. 2 Project History. - 16. 3 The COSY Program. - 16. 4 Hardware System. - 16. 5 Software. - 16. 6 Design of the Autopilot. - 16. 7 Future Development. - 16. 8 Conclusions. - 17. Satellite Attitude Control. - 17. 1 Introduction to the Attitude Control Problem. - 17. 2 Fault-tolerant Control of the 0RSTED Satellite. - 17. 3 Stabilization of the Angular Velocity of a Rigid Body. - 17. 4 Optimal Slew Maneuvers via Geometric Control Theory. - 17. 5 Attitude Control using Magnetorquers as Sole Actuators. - 17. 6 Predictive Attitude Control of Small Satellites. - 17. 7 Attitude Determination without Sensor Redundancy. - 17. 8 Summary. - Appendix A. List of Contributors. - Appendix B. List of Abbreviations. - References. Language: English
  • Marcă: Unbranded
  • Categorie: Educație
  • Artist: Karl J. Aström
  • Limbă: English
  • Număr de pagini: 482
  • Format: Paperback
  • Data publicării: 2012/09/27
  • Editor / Etichetă: Springer
  • ID Fruugo: 337872348-741531648
  • ISBN: 9781447110743
Promisiune

Garanția vânzătorului

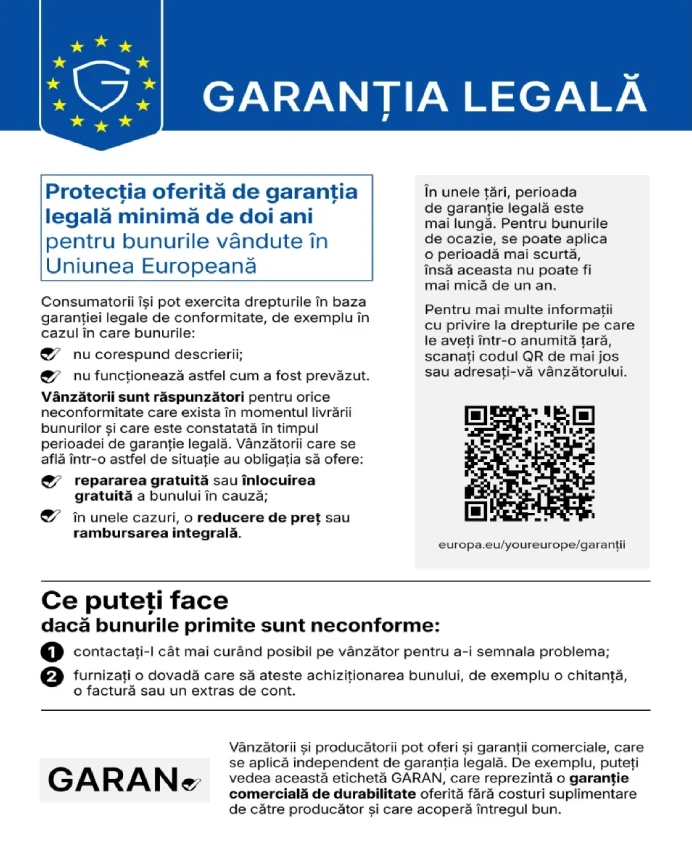
Garanție legală de 2 ani inclusă

Drepturile dumneavoastră de consumator din UE includ o garanție legală gratuită de minimum 2 ani

Descărcați garanția legală de conformitate
Livrare

Livrare

Expediat în 5 zile

  • STANDARD: 29,99 RON - Livrare între mar. 13 octombrie 2026–vin. 16 octombrie 2026

Livrare de la Regatul Unit.

Retururi

Returnări și anulări

Returnări

Facem tot ce ne stă în putinţă să ne asigurăm că produsele comandate de dumneavoastră vă sunt livrate în întregime şi conform specificaţiilor. Cu toate acestea, dacă primiţi o comandă incompletă sau articole diferite de cele comandate, sau aveţi alt motiv pentru care nu sunteţi mulţumit de comandă, puteţi returna comanda sau orice produse incluse în comandă şi primiţi o rambursare completă pentru articole.

Vizualizaţi întreaga politică de returnare

Anulări

Aveți dreptul de a retrage achiziția în termen de 14 zile de la primirea comenzii, fără a oferi un motiv. Pentru a vă exercita cu ușurință dreptul, puteți utiliza linkul „Anulați comanda” din subsolul fiecărei pagini sau din contul dvs. Fruugo, la secțiunea „Comenzi”. După ce vă exercitați dreptul de retragere, vă vom trimite un e-mail de confirmare. Dacă comanda dvs. a fost deja expediată de comerciant, vă vom oferi instrucțiunile de returnare necesare pentru a ne asigura că rambursarea dvs. este procesată prompt.

Vezi politica completă de anulare